10 Tips for Choosing Collaborative Robots in Manufacturing?
Choosing collaborative robots in manufacturing is not a simple equipment purchase. It is a practical decision about people, processes, safety, and long-term productivity. A cobot may look compact beside a production line, yet its real value depends on the task. Can it lift the required load? Can it reach every fixture? Will operators accept it during a busy shift?
Esben Østergaard, co-founder of Universal Robots and a recognized robotics expert, has said, “The future of robotics is collaborative.” That future requires careful judgment, not fashionable promises. The right cobot should support workers with repetitive, tiring, or physically demanding activities. It should also fit existing floorspace, tooling, software, and maintenance skills. Small details matter. A gripper that slips, a cable that blocks access, or a poorly positioned safety scanner can weaken an otherwise strong project.
This guide presents ten practical tips for choosing collaborative robots in manufacturing. It considers payload, reach, cycle time, programming, integration, safety, training, scalability, and total cost. It also encourages honest testing. No checklist is flawless. A robot that performs well during a demonstration may struggle with dust, variable parts, or frequent changeovers. Pilot runs, operator feedback, and documented measurements reveal those gaps. The best choice is rarely the most advanced model. It is the system that works reliably beside people, solves a defined production problem, and can improve without creating new ones.
Define Production Needs and Collaborative Robot Applications
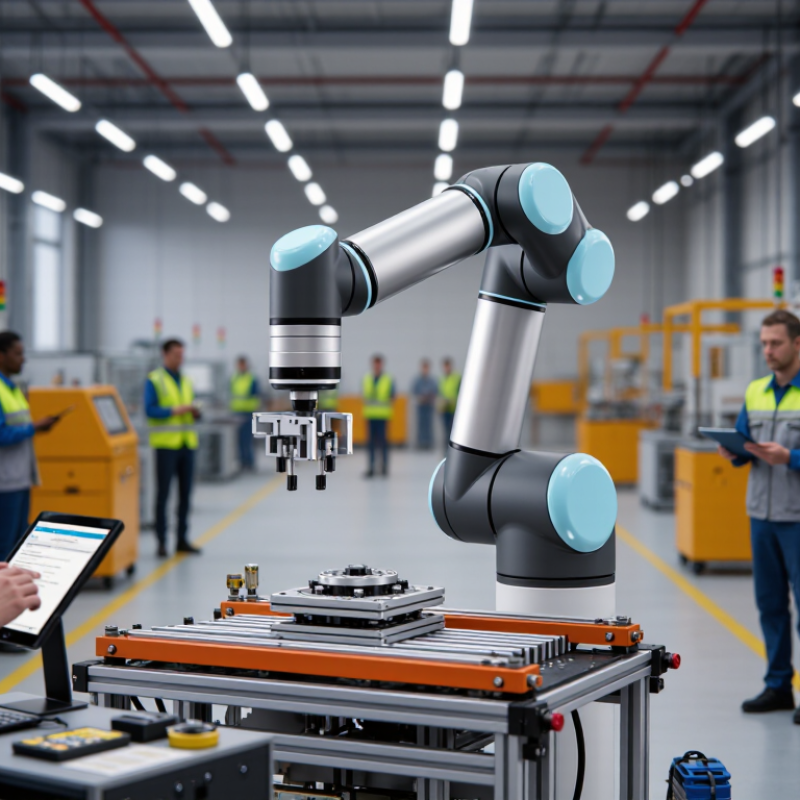
Tip 1: Define the production problem before comparing collaborative robots. Record cycle time, payload, reach, product dimensions, and daily operating hours. Observe the workstation during real production, not only during a clean demonstration. A spreadsheet rarely captures awkward parts or rushed handovers. Note where operators bend, wait, inspect, or repeat movements. These details reveal whether automation should support assembly, machine tending, packaging, inspection, or material handling.
Tip 2: Match the robot application to the process risk. Collaborative operation can suit low-speed loading, screwdriving, light assembly, and quality checks. It may not suit every high-force or high-speed task. Consider sharp edges, hot surfaces, unstable products, and unexpected motion. A documented risk assessment remains essential. Also check whether the robot can maintain accuracy after several hours, when dust or vibration appears. Small failures matter.
Tip 3: Design the complete application, not just the arm position. Define grippers, sensors, fixtures, software signals, and operator access together. The robot should stop safely when a person enters the shared space. It should also recover clearly after a fault. Ask who will adjust the station during a product change. If only one specialist understands the system, the design is incomplete. Test a representative workpiece, including difficult variations, before committing to equipment.
10 Tips for Choosing Collaborative Robots in Manufacturing? - Define Production Needs and Collaborative Robot Applications
| No. | Selection Dimension | Recommended Evaluation Data | Typical Manufacturing Application | Practical Selection Guidance |
|---|---|---|---|---|
| 1 | Define the Production Requirement | Part weight, cycle time, operating hours, batch size, takt time, and required output | Machine tending, assembly, packaging, and inspection | Choose the robot around the complete process rather than selecting a payload rating alone. Include tooling, grippers, fixtures, and the workpiece in the load calculation. |
| 2 | Match Payload Capacity | Common collaborative robot payload classes range from approximately 3 kg to 20 kg | Small-part assembly, screwdriving, material handling, and palletizing | Select enough capacity for the maximum combined load and wrist moment. A safety margin is advisable for acceleration, offset tooling, and future product variations. |
| 3 | Check Reach and Workspace | Typical arm reaches are approximately 500 mm to 1,800 mm, depending on robot size | CNC loading, bin picking, quality inspection, and workstation transfer | Map the robot envelope, fixture locations, operator access, and singularity areas. Do not rely on reach figures without testing the actual approach angles. |
| 4 | Evaluate Speed and Cycle Time | Joint speed, linear speed, acceleration, motion path, and measured cycle time under production conditions | High-mix assembly, dispensing, machine tending, and packaging | Collaborative operation may require reduced speed when people are nearby. Validate the complete cycle, including gripper actions, sensor checks, and waiting time. |
| 5 | Confirm Positioning Repeatability | Many industrial collaborative robots specify repeatability around ±0.02 mm to ±0.10 mm, depending on model and test conditions | Precision assembly, insertion, dispensing, screwdriving, and inspection | Distinguish repeatability from absolute accuracy. Use calibration, vision, compliance devices, or fixtures when the process requires tight part-to-part alignment. |
| 6 | Plan the Safety Concept | Risk assessment, force and speed limits, safeguarding, emergency stops, safe distances, and workplace layout | Shared workstations, loading operations, assembly assistance, and inspection | Collaborative capability does not automatically make an application safe. Assess the robot, end effector, workpiece, sharp edges, pinch points, and operating mode as one system. |
| 7 | Assess End-of-Arm Tooling | Gripper type, tool weight, gripping force, pneumatic or electric requirements, part geometry, and changeover time | Picking, kitting, screwdriving, sanding, welding, and surface treatment | The tool can significantly affect payload, reach, safety, and cycle time. Select tooling that securely handles the full range of parts and supports quick changeovers. |
| 8 | Review Programming and Usability | Teach pendant functions, graphical programming, template availability, operator training time, and changeover procedure | High-mix/low-volume production and frequent product changeovers | Simple programming can reduce deployment time and dependence on specialist personnel. Test whether production operators can safely make routine adjustments. |
| 9 | Verify Integration and Environment | Controller communication, digital and analog I/O, machine interfaces, vision compatibility, IP rating, temperature, dust, and washdown conditions | CNC cells, production lines, inspection stations, and automated packaging cells | Confirm compatibility with existing equipment and factory networks before purchase. Environmental protection requirements may require additional enclosure or installation measures. |
| 10 | Calculate Total Cost of Ownership | Robot, gripper, vision, fixtures, safety equipment, integration, training, maintenance, energy, and downtime costs | Any application where labor availability, ergonomics, consistency, or output is a concern | Compare the complete installed solution rather than the arm price alone. Estimate utilization, labor impact, maintenance needs, and the expected payback period. |
Note: Performance ranges are general industry reference values. Actual capability depends on robot configuration, tooling, payload position, safety settings, application layout, and operating environment.
Related Posts
-
Top 10 Collaborative Robots Transforming Industries Today?
-
2026 Best Collaborative Robots Transforming Manufacturing Industry?
-
10 Best Cobot Robots for Collaborative Automation in 2026?
-
Top 10 Tips for Implementing Robotic Systems in Your Business Successfully
-
How to Improve Robotic Systems in 2026 for Industry and Innovation?
-
2026 Best Robotic Systems Innovations and Trends for the Future?